Flight Controller
|
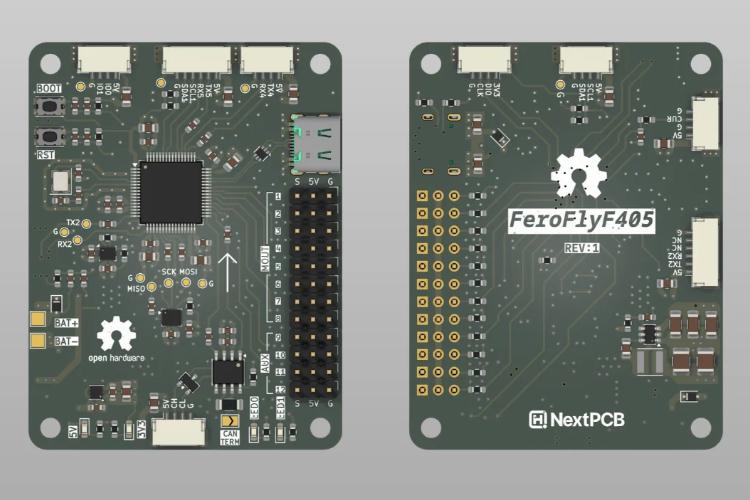
FeroFlyF405: An Open Source Drone Flight Controller Designed From Scratch on the STM32F405, With INAV Ported FeroFlyF405 is an open source flight controller built around the STM32F405 microcontroller and running INAV firmware. It was designed from scratch by a maker named Farhan, who shared the hardware files on GitHub and documented the build in a video walkthrough.
The board has an LSM6DSL IMU, a DPS368 barometer, 12 motor outputs, a CAN bus, an I2C port… |
|
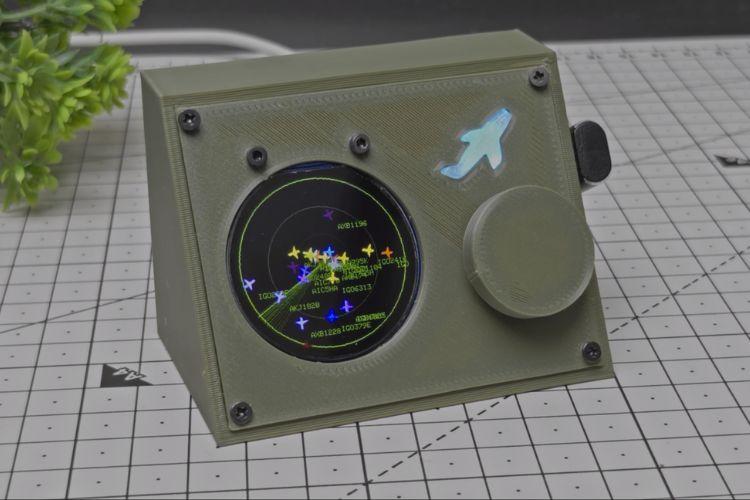
DIY Flight Tracker Using ESP32 This should be the easiest and cheapest way to build a flight tracker system. Maker from the Youtube Channel - Tech Talkies recently built this incredible DIY flight radar that runs entirely on an ESP32-S3 Zero, a round GC9A01 display and a rotary encoder. All the parts assembled onto a custom made 3D printed enclosure. Instead of capturing radio waves locally, it… |
|
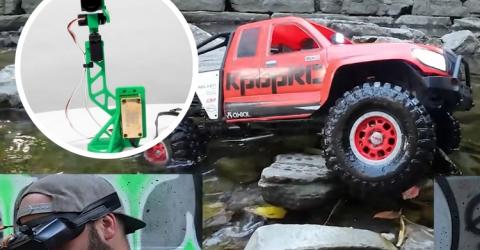
RC Jeep Uses a Servo-Powered Camera Rig for True Driver POV What if an RC car could make you feel like you’re actually sitting inside it? That’s exactly what creator kpopRC has built with his latest FPV Jeep crawler. Instead of a fixed camera, the system uses a servo-powered “lean-out” rig mounted in the driver’s seat position. This allows the camera to physically extend out of the window and move with pan and tilt controls giving a true driver’s… |
|
LiteWing ESP32 Drone IMU – MPU6050 Orientation, Euler Angles & Real-Time CRTP Telemetry Visualization In this guide, we explore one of the most important sensing modules in the LiteWing drone, the Inertial Measurement Unit (IMU). While the IMU isn’t located on the Flight Positioning Module, it’s a core part of the flight controller, providing orientation, angular rates, and linear acceleration, forming the backbone of all autonomous flight behaviors. … |
|
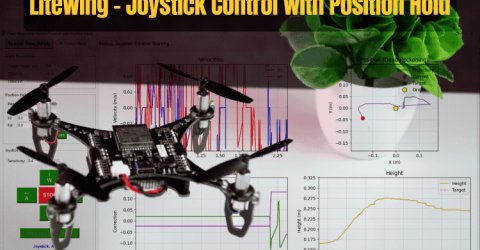
Drone Position Hold using Optical Flow Sensor – Joystick Control with Dead Reckoning (LiteWing Flight Positioning Module) In this guide, we will explore how to implement a control system where you can command the drone's movement using keyboard controls (WASD keys), and when you release those controls, the drone automatically maintains its position in space. This creates an intuitive flying experience where you get the precision of manual control when you need it, combined with the… |
|
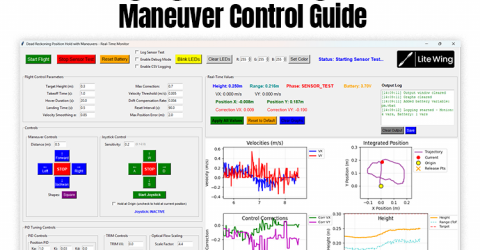
LiteWing Maneuver Control System – Autonomous Drone Navigation Using Optical Flow Sensor The Maneuver Control system is the final logical extension of the LiteWing Flight Positioning Module. While the Position Hold system focuses on maintaining a fixed point in space, maneuver control enables the drone to intentionally move to new positions while remaining fully autonomous and stabilized. The key distinction is that maneuver control does not introduce… |
|
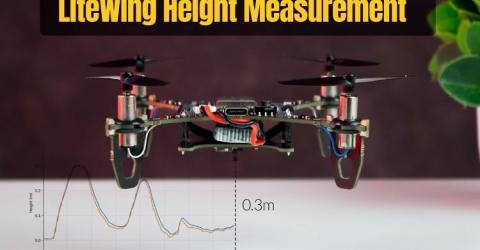
LiteWing Flight Positioning Module - Height Measurement In this section, we focus on one of the most immediately useful capabilities of the LiteWing Flight Positioning Module: precise height measurement using the VL53L1X time of flight sensor (ToF). Before implementing any control logic, it is essential to understand both the fundamentals of how the sensor measures distance and how the flight controller exposes this… |
|
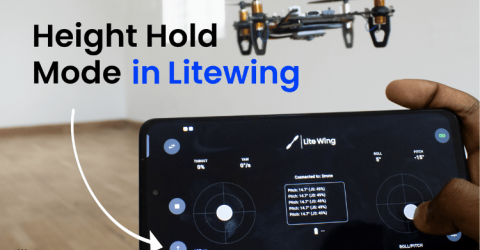
How to Use Height Hold Mode in LiteWing ESP32 Drone? Flying a drone manually requires constant attention to throttle control. One moment of distraction and your drone either crashes into the ground or flies away into the ceiling. If you're building your LiteWing from scratch, check out our detailed step-by-step LiteWing assembly guide to get started with your build. This is where Drone height hold mode becomes a… |
|
World's First Jet-Powered Hoverbike Opens for Preorder on August 1 A futuristic personal flying vehicle we previously covered will soon be available for pre-ordering. The Volonaut Airbike, developed by Polish inventor Tomasz Patan, is a jet-powered hoverbike. It is designed for a single rider and is capable of going as fast as 200 km/h. However, this is limited to 102 km/h for compliance reasons. A standout feature of the Airbike is its jet… |

|
Another Take on DIY ESP32 Drone, Now with Popsicle Sticks We’ve seen multiple DIY drone projects over the years, each bringing something unique to the table. At CircuitDigest, we even built our own version of a Wi-Fi controlled drone using the ESP32, which later evolved into LiteWing—an open-source drone development platform aimed at makers and researchers. Continuing in this spirit of accessible drone building, Vishal Sharma from the YouTube channel… |

|
DIY Rocket Guidance System That Actually Works If you have ever watched a rocket launch and wondered how it stays steady during its fast ascent, you are not alone. Rocket flying is not just about power, it is about control and precision. That is exactly what ‘BPS.space’ focused on their latest project. Before this project, the team worked on a few other rocket designs that helped them learn a lot about what works, and what doesn’t.… |

|
This Student-Built Satellite Turns Into a Drone While Landing Here is something you don’t see every day, a satellite that turns into a drone and guides itself back to the ground, without the help of a parachute. I Build Stuff youtuber recently made this happen for the CanSat competition, and honestly, it is one of those “simple idea, tricky execution” projects that ended up working out surprisingly well. Instead of using a parachute to land, like… |