Explore CircuitDigest’s collection of DIY drone projects created for beginners, hobbyists, and advanced makers interested in aerial robotics. Our drone-based projects show how to design and build drones using ESP32 microcontrollers, flight controllers, sensors, and wireless communication modules. Each tutorial includes clear explanations, circuit schematics, source code, and hardware setup steps to help you build and experiment with your own drone. By working through our hands-on projects, you can gain experience with flight control systems, robotics and embedded technologies.
Explore related project hubs: Artificial Intelligence | Electronics | IoT | Robotics | ESP32 | Raspberry Pi
The Maneuver Control system is the final logical extension of the LiteWing Flight Positioning Module. While the Position Hold system focuses on maintaining a fixed point in space, maneuver control enables the drone to intentionally move to new positions while remaining fully autonomous and stabilized. The key distinction is that maneuver control does not introduce…

Drones have rapidly evolved from niche hobbies to versatile tools with a wide range of applications, from photography to agriculture or even for defence and military purposes. Building a DIY ESP32 drone project is an affordable entry point into drone technology, with costs ranging from pocket change to commercial-grade systems. Even though the basic principle…
Most people assume object tracking for autonomous flight is very complex, but it doesn’t have to be that way. All you need is a different way of looking at the problem. We built this project to see if we could make a simple LiteWing drone behave intelligently using just a laptop and a basic camera.By placing the camera above the room ceiling, the floor becomes a…
Focused on versatility and modularity, the LiteWing drone can be programmed and controlled using different platforms. When you purchase a LiteWing drone, it ships with default firmware that supports Crazyflie protocols. This means out of the box, your drone is ready to fly using the mobile application, and also supports cfclient and cflib packages from Crazyflie.
Important…
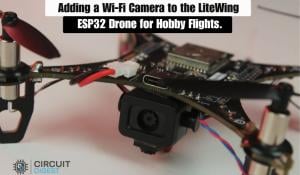
We love tinkering with our LiteWing ESP32 drone, and this time we gave it a simple but exciting upgrade, a WiFi camera module! With this addition, the drone can now stream live video while flying, perfect for hobby flights, aerial experimentation, or just having fun seeing the world from above.
On the technical side, the setup…
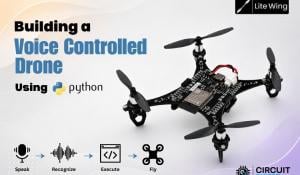
Drones are amazing little machines, but most of the time they are controlled using remotes filled with buttons and joysticks. While experimenting with our LiteWing drone, we started wondering, wouldn’t it be cool if the drone could simply listen to what we say? That idea eventually turned into this project. We built a voice controlled drone using ESP32 for the…
LiteWing is an open-source ESP32-S3 based drone that offers a flexible platform for experimentation and learning. By default, LiteWing operates using the modified Crazyflie firmware. LiteWing can also be configured using Betaflight, a powerful and widely adopted flight control software used in FPV and racing drones.
In this ESP32…
In this section, we focus on one of the most immediately useful capabilities of the LiteWing Flight Positioning Module: precise height measurement using the VL53L1X time of flight sensor (ToF). Before implementing any control logic, it is essential to understand both the fundamentals of how the sensor measures distance and how the flight controller exposes this…
In this project, we upgraded LiteWing, an ESP32-based development drone by adding a lightweight Bluetooth speaker system to extend its capabilities beyond flight. By adding a simple Bluetooth audio setup, the drone can now deliver real-time announcements, voice messages, or music directly from the air without requiring any additional coding. The entire system works…
The LiteWing Drone Flight Positioning Module enables autonomous position hold capabilities using optical flow sensors combined with dead reckoning algorithms. This guide explores how to implement a fully autonomous position hold system where the drone takes off, hovers at a target height, and actively maintains its position in space without manual intervention. This…
In this guide, we focus on the WS2812B addressable RGB LEDs on the LiteWing Flight Positioning Module. The module includes four NeoPixel-compatible LEDs, each independently controllable via software. These LEDs are useful for flight status indication and visual debugging during development. A curated collection of hands-on drone projects with guides showing how to…
In this guide, we explore one of the most important sensing modules in the LiteWing drone, the Inertial Measurement Unit (IMU). While the IMU isn’t located on the Flight Positioning Module, it’s a core part of the flight controller, providing orientation, angular rates, and linear acceleration, forming the backbone of all autonomous flight behaviors.
…