



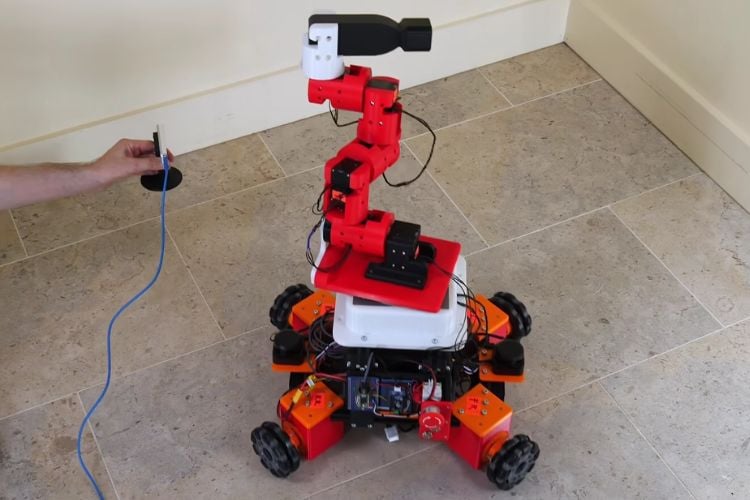
James Bruton has built an open-source 7-DOF tentacle robotic arm that treats each joint as a 90° rotating stage, creating a highly flexible manipulator that can wrap around obstacles and reach into tight spaces. The design uses multiple Dynamixel servos chained into a serial kinematic chain, with custom 3D-printed links and structural parts to form a lightweight, compliant “tentacle” rather than a traditional rigid industrial arm.
The arm is fully integrated into ROS 2, with MoveIt configured to solve inverse kinematics. This setup lets the tentacle find multiple valid joint configurations for a given end-effector pose, enabling smooth, collision-aware motion planning and making it easier to exploit the extra degrees of freedom for dexterous tasks and constrained environments.
To further extend its capabilities, the tentacle is mounted on a holonomic, omni-directional mobile base, effectively adding extra axes to the system and dramatically expanding its reachable workspace. The combination of a redundant 7-DOF arm, ROS 2 MoveIt IK, and a holonomic platform makes this project a strong reference for researchers and makers exploring soft-inspired manipulators, mobile manipulation, and advanced motion planning in real-world scenarios.
A New Approach to Robotic Manipulation
James Bruton’s open-source 7-DOF tentacle arm combines Dynamixel servos, 3D-printed parts, ROS 2, and MoveIt for flexible motion and advanced inverse kinematics. Mounted on an omni-directional base, it offers impressive mobility and reach in constrained environments.