ros 2
|
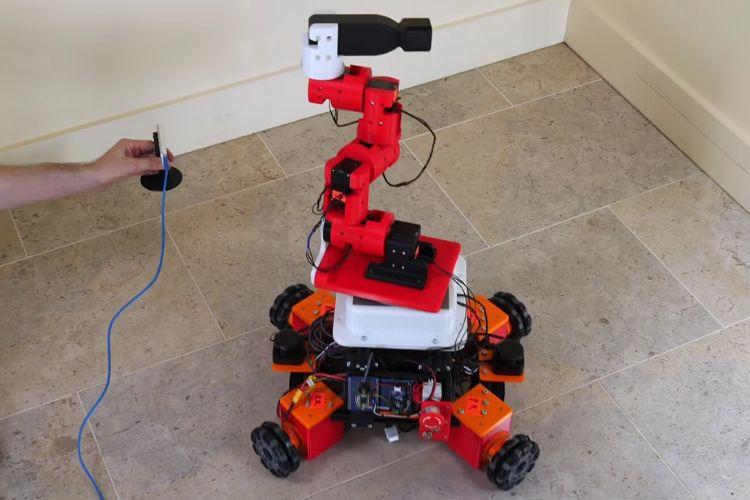
Open-Source 7-DOF Tentacle Arm Uses ROS 2 MoveIt for Inverse Kinematics and Features a Holonomic Base James Bruton has built an open-source 7-DOF tentacle robotic arm that treats each joint as a 90° rotating stage, creating a highly flexible manipulator that can wrap around obstacles and reach into tight spaces. The design uses multiple Dynamixel servos chained into a serial kinematic chain, with custom 3D-printed links and structural parts to form a lightweight, compliant “tentacle” rather… |
|
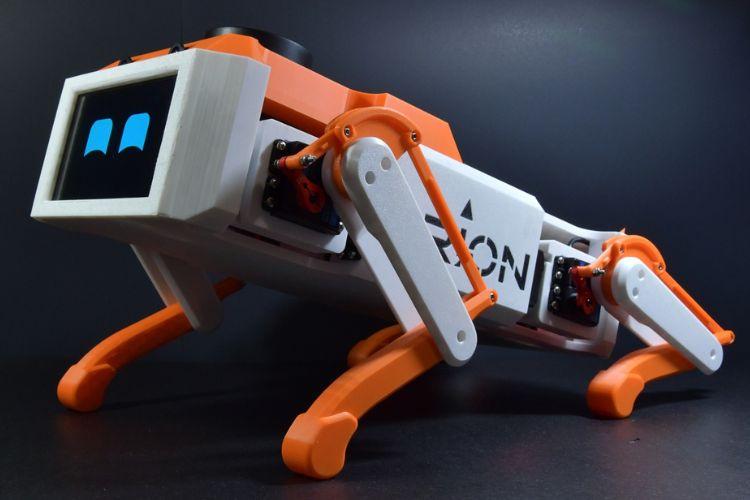
Maker Builds a 12-DOF ROS 2 Quadruped Using Jetson Orin Nano for Vision and STM32 for Real-Time Control Ashish Agrahari, a Mechatronics Engineering student at the University of Waterloo, has recently built Orion, a 12-DOF quadruped robot dog designed and programmed from scratch over eight months, combining ROS 2 autonomy with custom embedded electronics. The system is split into two layers: a Jetson Orin Nano for high-level perception and planning, and custom STM32-based PCBs for deterministic,… |