moveit
|
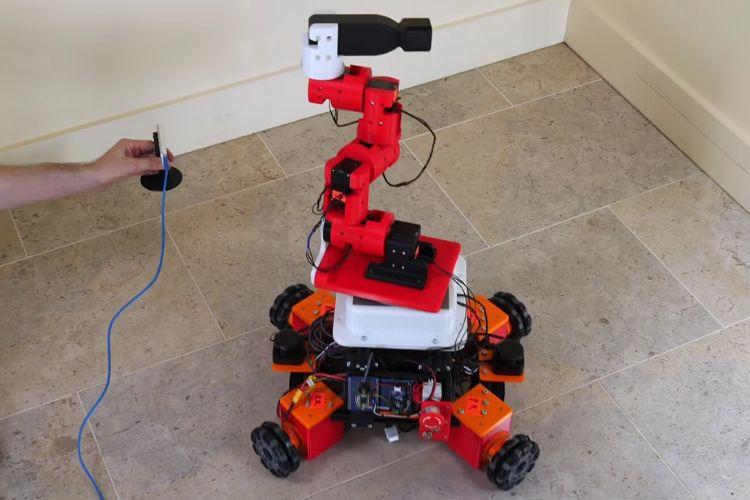
Open-Source 7-DOF Tentacle Arm Uses ROS 2 MoveIt for Inverse Kinematics and Features a Holonomic Base James Bruton has built an open-source 7-DOF tentacle robotic arm that treats each joint as a 90° rotating stage, creating a highly flexible manipulator that can wrap around obstacles and reach into tight spaces. The design uses multiple Dynamixel servos chained into a serial kinematic chain, with custom 3D-printed links and structural parts to form a lightweight, compliant “tentacle” rather… |