 Anand D
Author
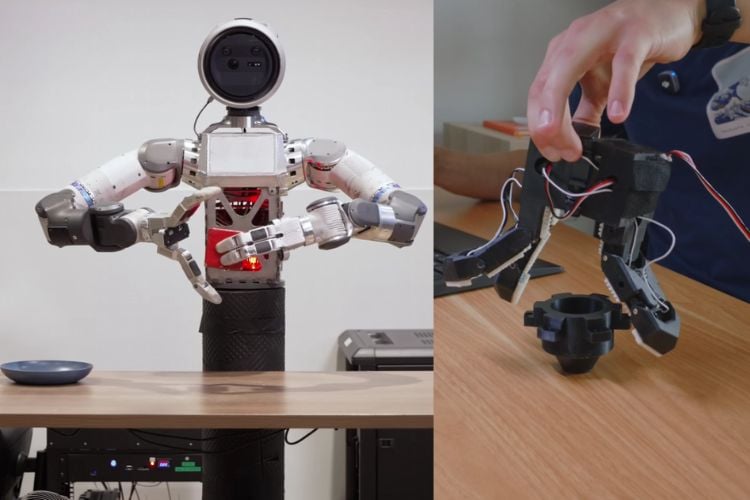
Maker built a Boston Dynamics–style gripper using daisy‑chained bus servos and 3D‑printed fingers. Inspired by the Electric Atlas Humanoid Robots, the design focuses on a simple three‑finger layout with a rotating thumb to move around objects of different shapes. By linking multiple servos over a single UART bus, the build keeps wiring clean while allowing independent control of each joint for more natural grasping.
The mechanical side combines CAD modeling with resin and FDM prints to balance strength and weight. He also demonstrated how the Feetech servo motors differ from the normal SG90 servo motors. Power distribution and servo addressing are handled through a small controller board that manages the daisy chain, making it easy to tune limits, speeds, and grip profiles in software.
Control is demonstrated with a USB webcam and basic hand‑tracking, turning the gripper into a low‑cost teleoperation tool. As the user opens and closes their hand, the same motion is mirrored by the 3D‑printed fingers, showing how vision‑based input can replace complex teach pendants. The result is a desktop‑scale replica that captures the spirit of Boston Dynamics’ hardware while staying accessible to makers working with off‑the‑shelf servos and consumer 3D printers.