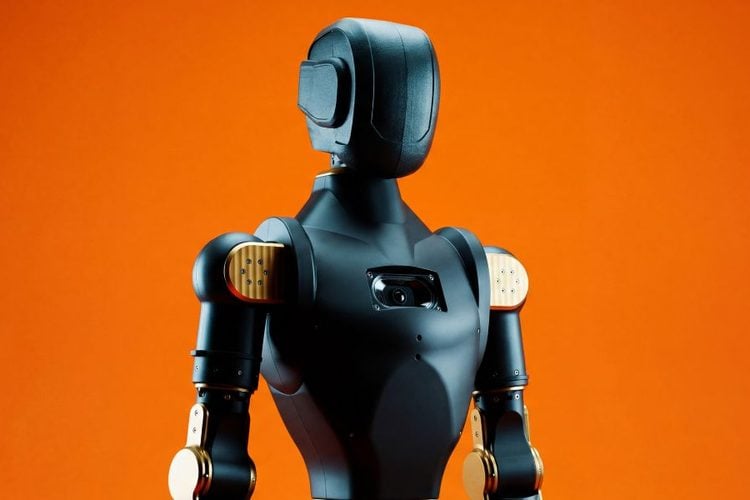
Most humanoid robots you see walking on stage are closed products with closed software. Asimov 1 is the opposite. Menlo Research, a team in Singapore, has published the full mechanical CAD, electrical schematics and PCBs, simulation models, firmware and walking policy for its 1.2 m, 35 kg humanoid, and on day 366 of the project the robot was out in public at the SWITCH event in Singapore, walking among visitors with a newly trained locomotion policy. The GitHub repository has passed 1,300 stars.
What is inside
Asimov 1 has 25 powered joints: six in each leg, five in each arm (three at the shoulder, the elbow and a wrist yaw), one at the waist and two in the neck. The structure is 7075 aluminium plus MJF-printed PA12 nylon, and it runs on a 13S4P lithium-ion battery pack.
The computing is split in two. A Radxa CM5 runs motion control, and a Raspberry Pi 5 handles media and networking. The joints talk over six CAN buses (five at 1 Mbps and one at 500 kbps). For sensing it has an IMU, a 2 MP camera, a stereo microphone array and a 10 W speaker. Menlo rates the arms at 5 kg each for curls and front raises, with peaks of 15 kg.
How it learned to walk
The walking controller is a neural network policy trained in simulation with NVIDIA Isaac Lab, using PPO reinforcement learning with adversarial motion priors, a method that nudges the robot towards natural-looking human motion. The released policy runs at 50 Hz: every 20 ms it reads 78 values (body angular velocity, gravity direction, the commanded speed, joint positions and velocities, and its previous action) and outputs target positions for 23 joints. The neck is locked while walking.
Menlo publishes the policy checkpoints on Hugging Face as ONNX and TorchScript files, along with the training code, and says policies trained on its MuJoCo and URDF models can be deployed to the real robot with no extra tuning. The firmware image for the CM5 already includes the walking policy, so a freshly built robot can walk from velocity commands, and a direct joint-control mode supports teleoperation. A full SDK and an emulator are still in development.
Key details
- Size: about 1.2 m tall, about 35 kg
- Joints: 25 powered (6 per leg, 5 per arm, 1 waist, 2 neck)
- Compute: Radxa CM5 for motion control, Raspberry Pi 5 for media and networking
- Sensors: IMU, 2 MP camera, stereo microphones, 10 W speaker
- Walking: RL policy trained in Isaac Lab (PPO with AMP), 50 Hz, 78 inputs and 23 joint outputs, released as ONNX
- Licences: hardware under CERN-OHL-S-2.0, software under GPL-2.0
- Files: Asimov 1 on GitHub and the Asimov 1 docs; a DIY kit is also listed
Our take
A humanoid at this size with every layer open, from the CAD to the walking policy, is rare, and it gives universities and robotics clubs something real to study, modify and train on rather than a black box. The split of a Pi 5 for media and a CM5 for control is also a sensible pattern for anyone building a large robot. Walking in a crowded public space is a tougher test than a lab floor, so the next updates on how the new policy copes will be worth watching.
Image credit: Menlo Research (Asimov 1 GitHub repository), cropped and resized.
About the author: Aswinth Raj is an electronics engineer and the editor of CircuitDigest, where he has published more than 150 hands-on projects and tutorials across Arduino, PIC, ESP32, Raspberry Pi and EV battery systems. He selects the stories on this page for what engineers and makers can actually learn or build from. Connect on LinkedIn
Add a comment
No account needed. Your comment appears once a moderator has reviewed it.