
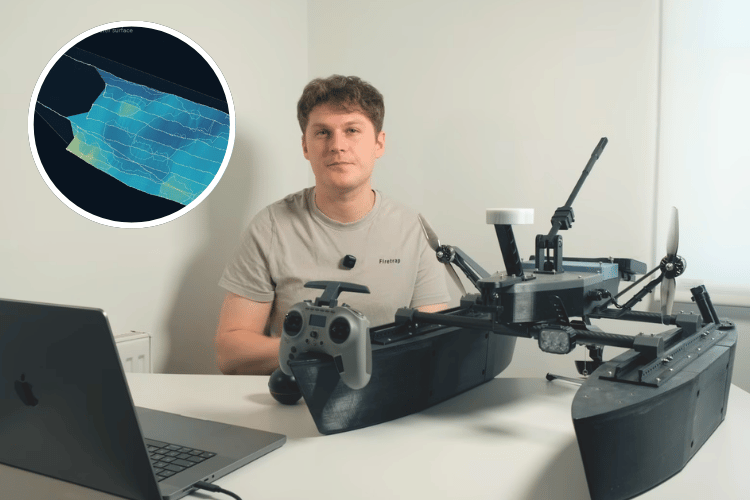
An autonomous 3D-printed catamaran built by hobbyist Cy Antony Ash has mapped the depth of a lake in North Wales, the result of a two-year build. The boat carries a Deeper castable fish finder along a programmed route across Llyn Celyn, so the sonar no longer has to be cast from a rod. Instead of underwater propellers, it uses drone motors mounted above the waterline, which keeps the props clear of weeds, and it steers by varying thrust between two motors, so no rudder is needed. Navigation runs on ArduPilot, using waypoint missions and a return-to-launch function.
The hulls went through several revisions. Early versions sat low in the water once the equipment was loaded, so the builder moved to larger 3D-printed hulls made in sections and filled with two-part buoyancy foam. One hull was pushed apart as the foam expanded and had to be reprinted. The sections are joined with bolts and brass threaded inserts, so damaged parts can be replaced individually. Connectivity was another recurring problem. The first radio setup gave limited range, so the builder switched to a 900 MHz mLRS link with the antenna on a folding mast. The fish finder runs on its own Wi-Fi connection, which dropped out at roughly 50 metres, so a second phone now rides on the boat next to the sonar and saves the recordings on board.
The first grid survey completed its route, but the phone glitched in the cold and failed to save the data. A repeat run with an older iPhone worked, returning just over 3,000 depth readings, each tied to a position. Software then estimated a lakebed surface between the measurement lines, which the creator stresses is an estimate, not a confirmed picture of anything underwater. The final boat and controller cost roughly £550, excluding the fish finder, phone and earlier prototype parts. The build was documented in a YouTube video posted on October 11.
Add a comment
No account needed. Your comment appears once a moderator has reviewed it.